Towards Edge AI computer vision

kyrylo.sh

I build computer vision pipelines to run on edge devices. Edge AI enthusiast and owner of an Nvidia Jetson Orin Nano.

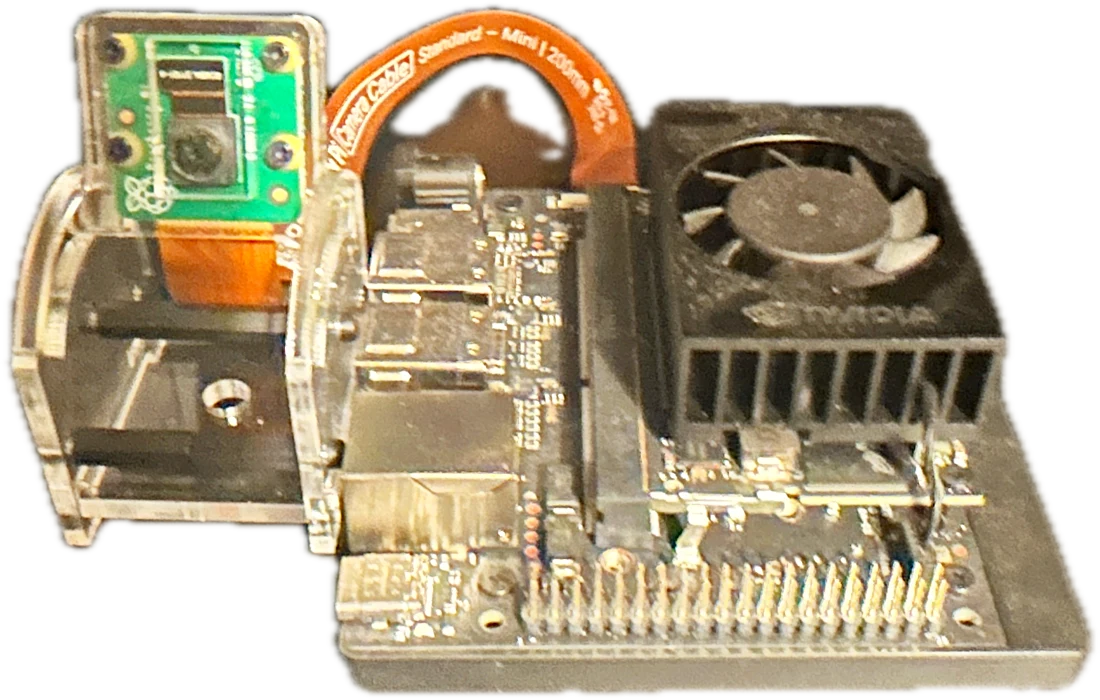
jetson-orin-nanoNvidia Jetson Orin Nano connected to a Raspberry Pi camera module by an orange ribbon cable.

2026

LPRTOS

Laser-prompted real-time object segmentation on smartphones via cloud computing. Point a green laser at an object and the phone shows its mask. Official implementation of the published paper.

16 ms
per frame, L4 GPU, TensorRT
42 ms
per frame, Jetson Orin Nano, TensorRT
2,209
images in the released benchmark dataset
  • YOLOv5
  • FastSAM
  • TensorRT
  • Jetson Orin Nano
  • Android
  • Kotlin
  • Docker

2026

PointRead

Point at a word or sentence in a paper book and hear the translation. A hand-tracking, OCR, translation and speech pipeline running on an Nvidia Jetson Orin Nano.

8
target languages, each with its own voice
21
hand keypoints tracked in real time
Headless
runs with only a camera and a speaker
  • RTMDet
  • RTMPose
  • PP-OCRv5
  • TensorRT
  • Jetson Orin Nano
  • OpenCV
  • Docker

Want to talk about computer vision or edge AI? Find me here: